
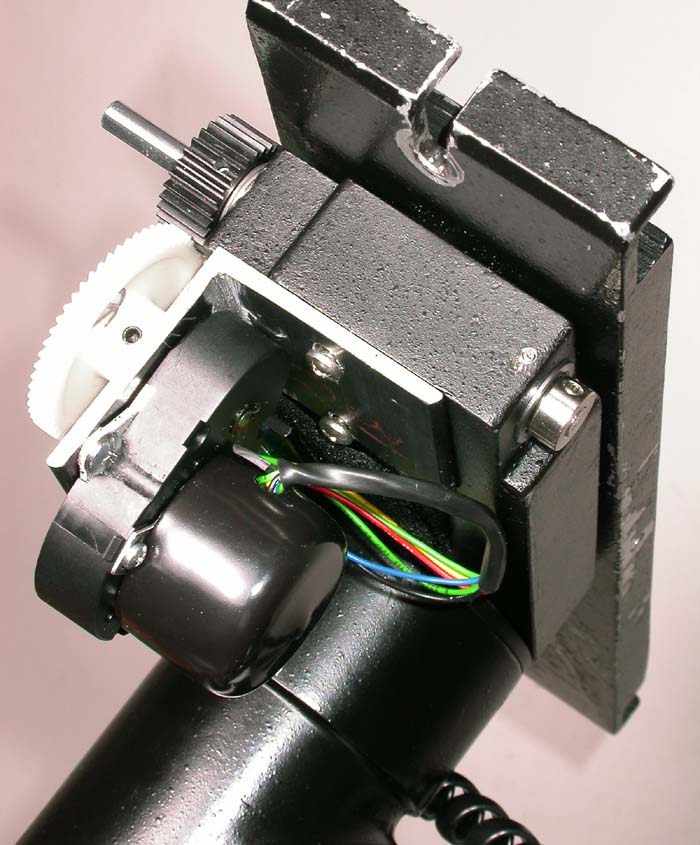
This is the Dec motor. The origional tangent arm used a big knob on a spring loaded lead screw. The spring pressure was pretty high and the motor wouldn't turn it properly. I changed it to a 1/4-20 threaded rod running in ball bearings. MUCH smoother. The gearing works out to give a basic dec rate of 2.5 arc sec/sec at the lowest rate speed of .3 siderial. I think that will be plenty fine enough for smooth dec corrections but when you bump the rate up to 16x that puppy flies!
Walt
Walt
Attached Image:
