Image of the day

Captured by
Craig Bobchin

Coathanger CR 399

My Account

New to Astromart?

Register an account...

Need Help?

Quick-Release Tangent Drive??

Started by P. Lee Stock, 10/24/2003 06:00AM
Posted 10/24/2003 06:00AM Opening Post
Last week I would probably have sworn all the world needed was a better understanding of the half-nut; today, threaded rod couldn't be straight enough and I'd have given anything for a .316" reamer .

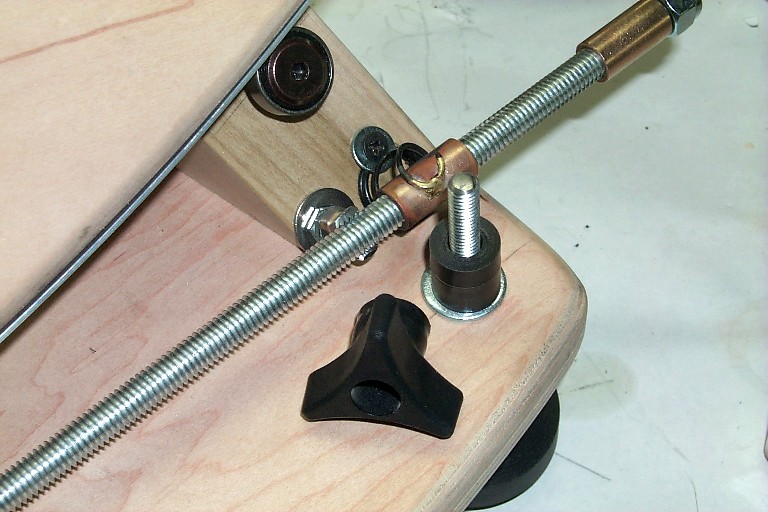
This is an untested EQ platform concept, as of yet, but I wanted to show you guys what I came up with.

So, as it goes, I had decided there really wasn't a good reason why a tangent driven EQ platform with instant reset couldn't exist (does it??--I've never seen one) and set about to rectify the problem of having to rewind the drive nut to start position and other such silliness with a concept that's been in my head for the past few months. I powered it up today and, while I'm sure it will work, I may be surprised, or not, to find periodic error unacceptable. The difficulty lies in the linkage between the motor and threaded rod... and perhaps the straightness of the threaded rod itself.

(continued...)


Attached Image:
P. Lee Stock's attachment for post 10188
Posted 10/24/2003 06:14AM #1
(...continuation)

I hadn't considered that the threaded rod would need to join to the motor absolutely centered on the motor's drive shaft and turn perfectly in line with the motor--and the closer, the better. Hence my search for a way to drill a perfectly sized hole in the barrel connecting the motor shaft to the leadscrew (***Please see my plea for help below ;^).

If the threaded rod does *not* turn perfectly in line with the motor's shaft, due to oversized or off-center linkage, the rod will wobble the motor up and down as it turns just enough to pivot the tangent joint and cause the table to move forward a bit, pause, and maybe even go backward a few thousandths before moving forward again. Dab'nabit ;^).

Still, you *can* reset it in 1.5 seconds and it might work great anyway as is, or after I make the perfect connector (got fingers crossed). I'm always looking for ways to make things more convenient while observing, so cranking a nut back to start position, or doing a 4-minute electronic rewind just didn't make sense to me.

_____________________________________________________

***Plea for help!! :

I could actually use some machining advice here--I assume that if my motor shaft is .315", going up just .001" to a .316" reamer is sufficient? Too much? Not enough? I really want to squeeze this motor shaft into a connector that barely fits it, so please send your recommendations on sizing a *really* tight hole. Thanks!


Attached Image:

P. Lee Stock's attachment for post 72443
Posted 10/26/2003 10:36AM #2
Short version: It works really well--what was I worried about?

Longer version: At 305x (4mm ortho, 8" f/6) an image placed in the center FOV moves around a little bit--perhaps 1/3 of the total available FOV in a ~45-degree apparent field eyepiece over about 45 seconds. In other words, you won't be doing astrophotography with it, but it works really well, even at high powers.

After straightening the threaded rod to the point where turning one end only resulted in movement of around .01" at the other end, and making a really tight connector, a dial indicator measuring the movement of the table showed a steady drop over approximately .08", then a couple second pause, then the steady movement again. No backtracking.

By far the greatest challenge with tracking was simple polar alignment and first-time leveling. Once these were close (via drift method--could hardly find Polaris in the sky glow tonight), everything simply worked.

It is surprising how forgiving and easy the EQ platform concept is. Yes, I was careful in designing and building, but this was my very first attempt at one and the thing worked great right out of the chute. I even got the motor speed and threaded rod per inch thread count right.

Only thing to improve is I need a better potentiometer--I placed slightly too much resistance on the circuit to power it down to a range my available pot could deal with and during the last 5 or 10 minutes of "climb", the motor doesn't have quite enough speed/torque to keep up--and if I bypass the pot and run full speed, it tracks just slightly fast. So I need a speed just shy of "full", something not available as currently wired. For the other 60 or 70 minutes (of 90 total), it tracks just great.

Oh, and the best part... I reset it 3x tonight and that took around 5 seconds total, counting all 3 times ;^). NO rewind procedure to clutter up the observing experience--just like I wanted.